
Overview
The company delivers generative AI workflows and intelligent agents that transform manual scenario development into rapid, scalable simulations for mobility innovators. Deontic's tools integrate with development environments like Visual Studio Code to enable scenario generation, visualization, and ODD coverage analysis.
Key people
In the news
- Come meet me in Michigan next week. I'll be showcasing how Deontic transforms natural-language requirements into ASAM e.V. OpenSCENARIO/OpenDRIVE scenarios, parameter sweeps, coverage metrics, and traceable validation evidence. If you’re working on ADAS/AD validation, simulation, safety, or homologation, come visit our booth at Vehicle Tech Week #AV610 in Novi.
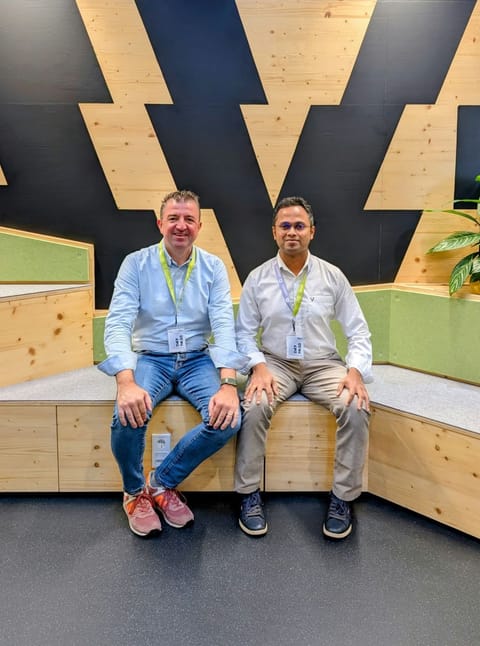
- We’re expanding Deontic, both our leadership team and our engineering footprint. We’re very happy to welcome Pramod Gurudatt, PMP as our new CTO. Pramod brings more than 11 years of experience across autonomous driving, systems engineering and AI powered automotive product development. Most recently at CARIAD, he led the strategy and roadmap for a GenAI powered ADAS scenario generation platform, following earlier engineering roles at Aptiv, ZF and Mercedes Benz R&D. His background sits exactly at the intersection of automotive
- Simulation-first is no longer optional. As ADAS and autonomous-driving programmes scale, the real bottleneck is shifting from simulation capacity to validation coverage, traceability and evidence. That’s exactly what our CEO Stephen Lernout will be talking about at Vehicle Tech Week North-America. 🎤 Simulation-First Validation: Turning Autonomy Requirements into Regulator-Ready Scenarios at Scale 📍 Novi, Michigan 📅 28 October 2026 ⏰ 15:45–16:00 🎯 Day 2 PM | Technical Considerations and Scaling At Deontic, we’re building an
- Come and meet me in Sinsheim👋 I'll be exhibiting and presenting with Deontic, showing how we turn #ODD definitions, engineering #requirements and #regulatory constraints into simulation-ready scenarios, coverage plans and traceable validation evidence. Together with IPG Automotive #VIRTO and #CarMaker, we’re demonstrating how virtual testing can move beyond scenario generation toward scalable, auditable validation assurance. See you next week! b-plus Group Marius Reuther Chris Richardson
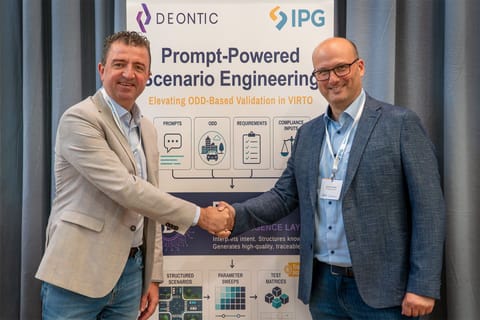
- Proud to officially kick off our partnership with IPG AutomotiveI together with CEO Steffen Schmidt. The challenge we are tackling is simple to describe, but difficult to solve: how do you turn requirements and ODD definitions into scalable, traceable and validation-ready scenarios? By combining Deontic's AI-driven scenario generation with IPG Automotive’s #VIRTO and #CarMaker ecosystem, we are connecting the workflow from natural-language requirements and ODD constraints all the way to managed simulation scenarios and
- We’re heading to Karlsruhe! 🇩🇪 Deontic CEO Stephen Lernout will be exhibiting and presenting at IPG Automotive’s Apply & Innovate 2026 on September 16 and 17. Simulation scales. Validation logic often doesn’t. As regulations evolve, ODDs expand and scenario libraries explode, the hard part is no longer running more tests, it is deciding what to test, why it matters, and proving coverage is defensible. At Apply & Innovate, we’ll show how prompt-powered scenario engineering turns requirements, regulations and ODD constraints into
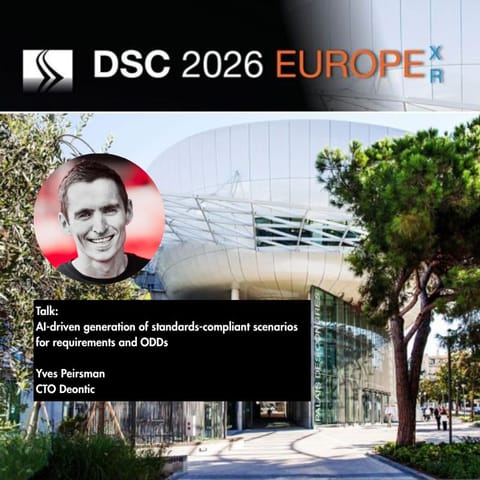
- Meet Deontic at DSC 2026 Europe XR in Antibes. From 16 to 18 September, our CTO Yves Peirsman will be on site at the 2026 Driving Simulation Association Conference, exhibiting and presenting on how generative AI can turn requirements and ODDs into standards-compliant simulation scenarios. ADAS and AD validation is still too slow: engineers spend weeks hand-crafting scenarios for every new geography and operational design domain, while legislation and standards keep moving. At DSC we’ll show how Deontic closes that gap: -
- Yesterday our CTO Yves Peirsman travelled to a sweltering Paris to present Deontic at the HERE Technologies Tech day. Together, Here and Deontic make it easy to generate driving scenarios for real-world environments: 🌎 search for a suitable location with Here SceneXtract, 📁 export the map as an ASAM e.V. OpenDRIVE file, and 🚗 use Deontic to create driving scenarios in that location. Validating the behavior of your vehicle in real-world locations couldn't be simpler. Thanks to Here for the invitation and the perfect


Something wrong or missing? Send an update. Fixed within 24 hours.